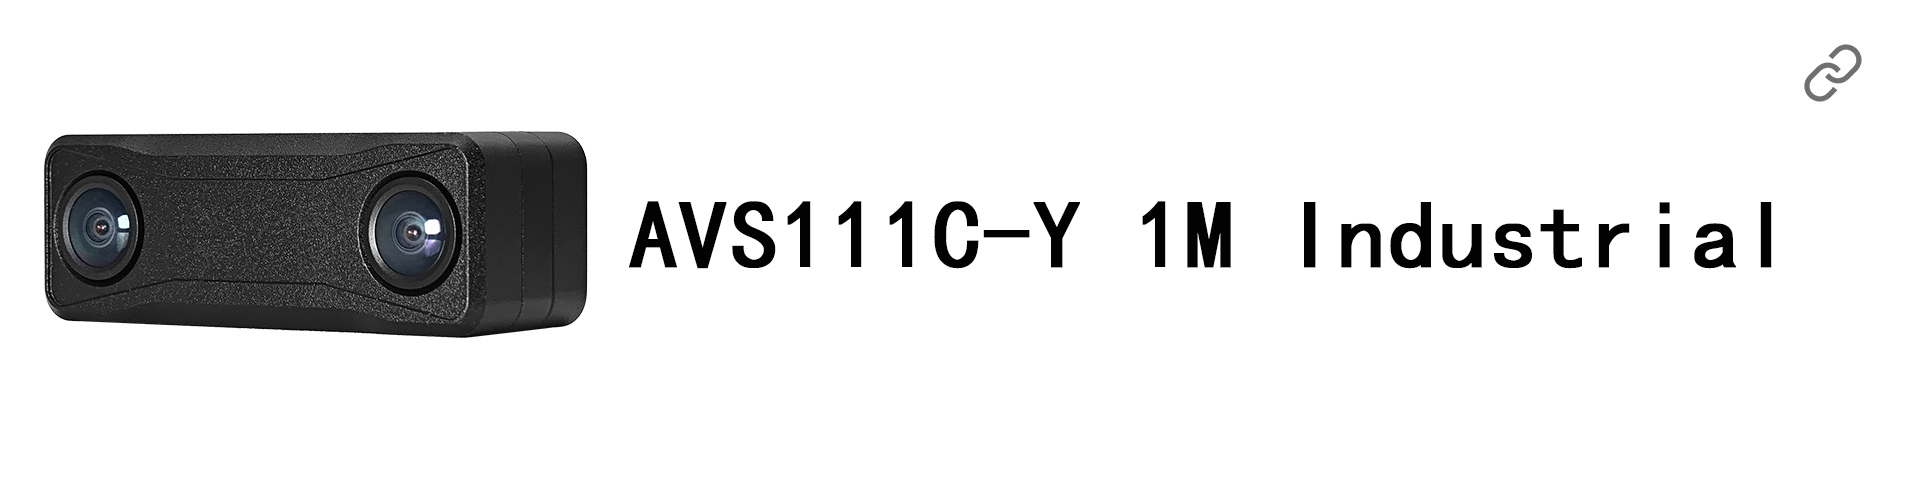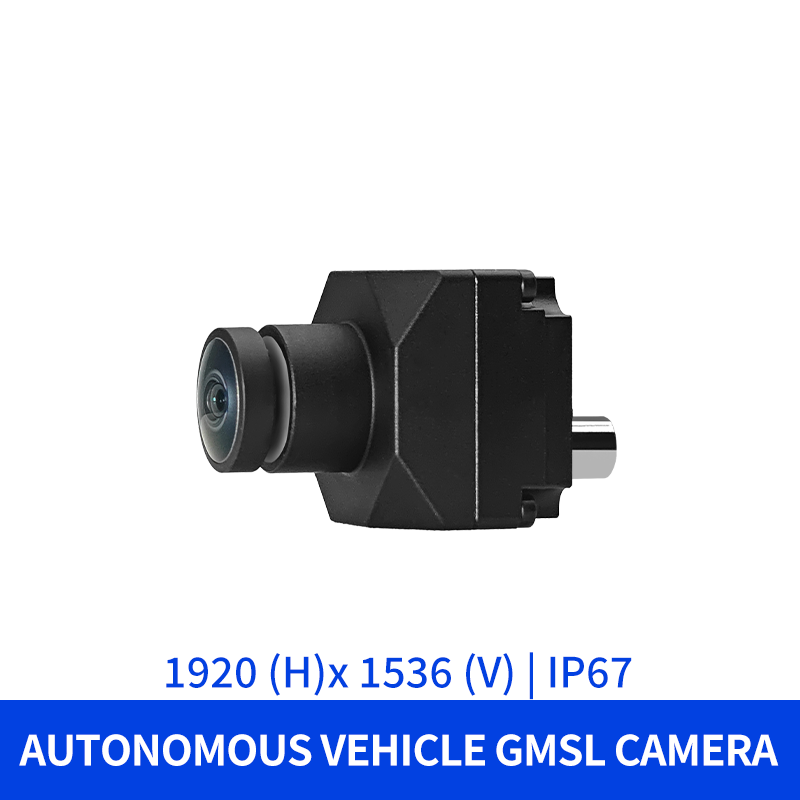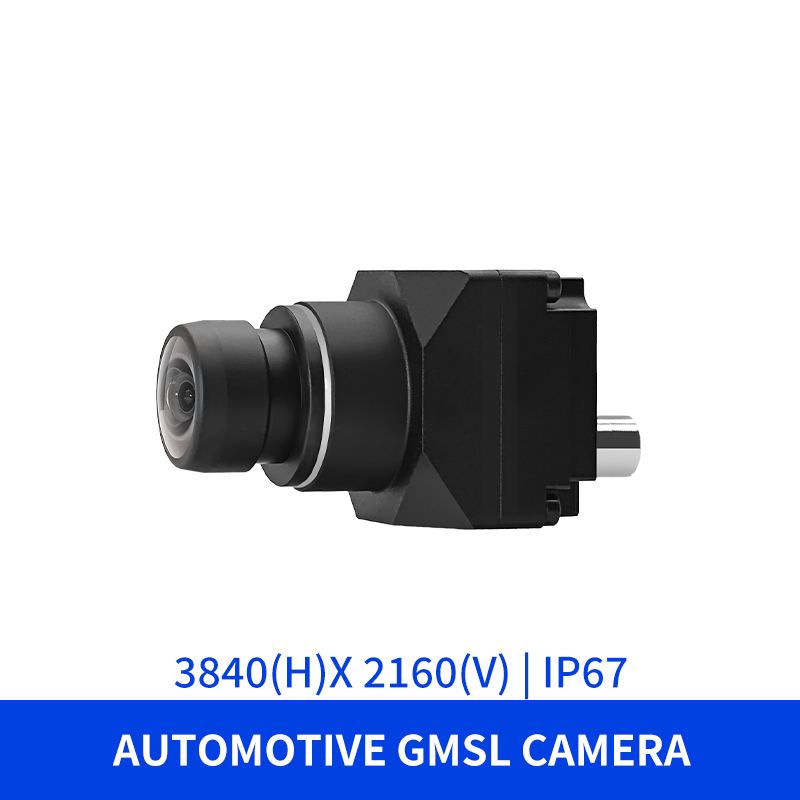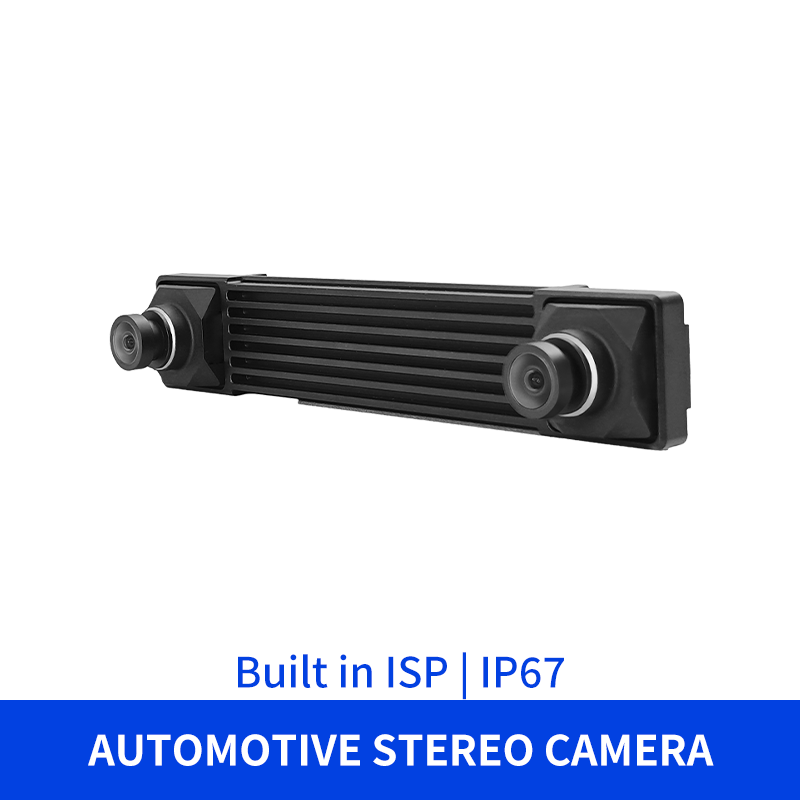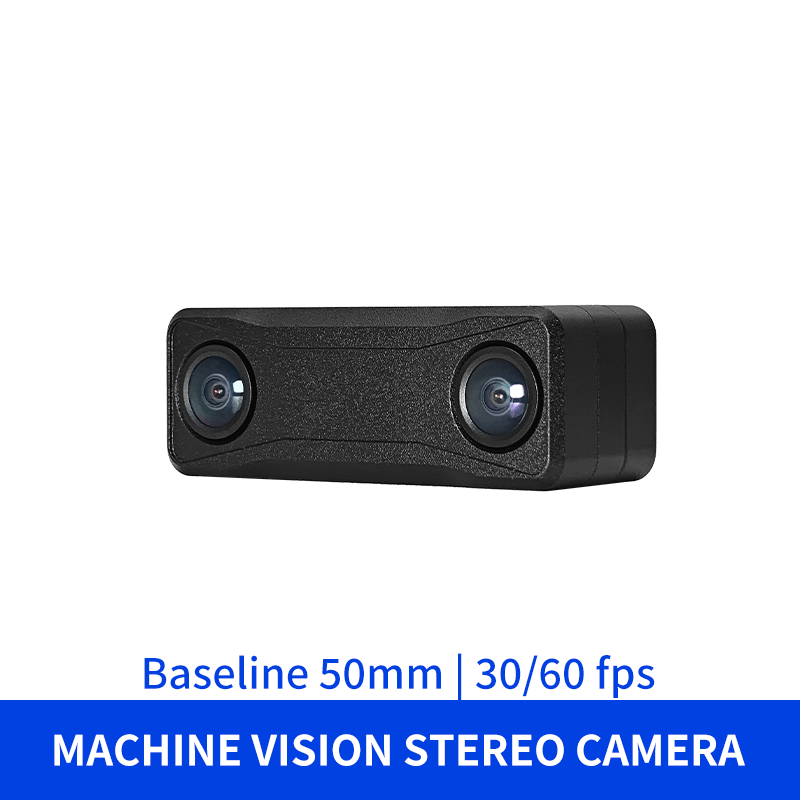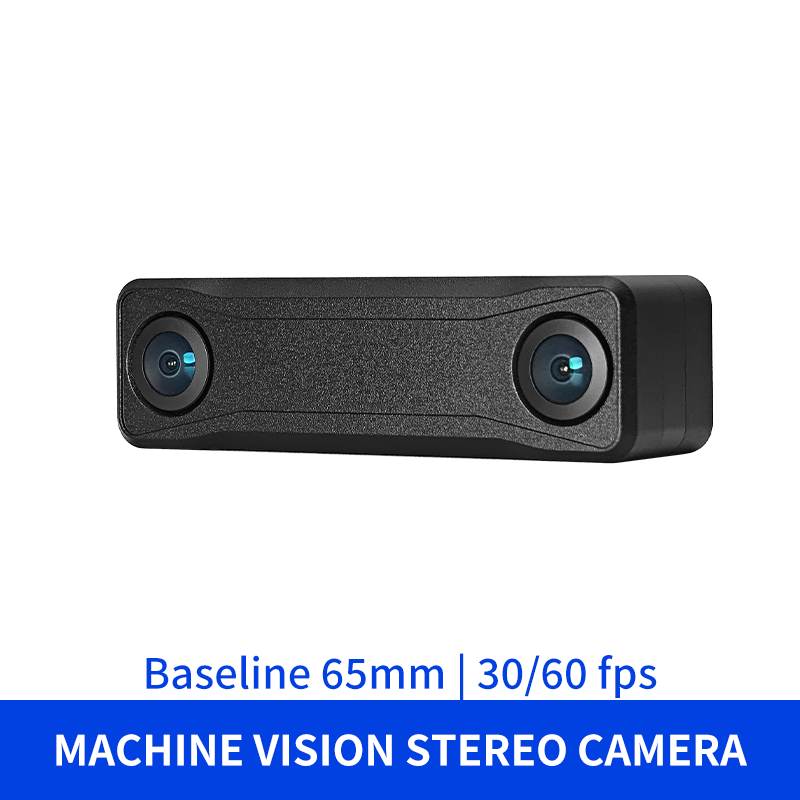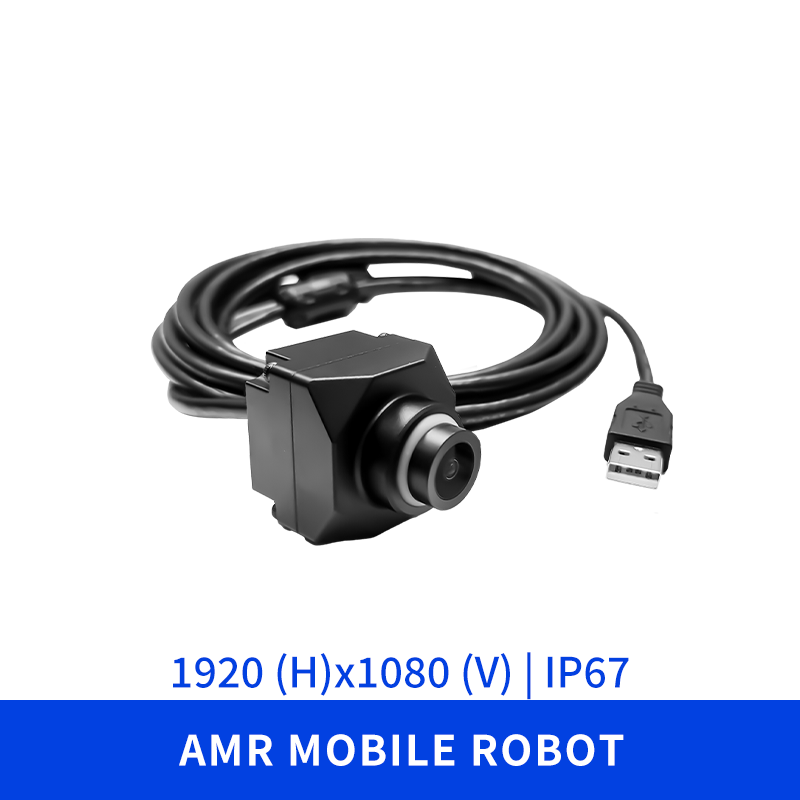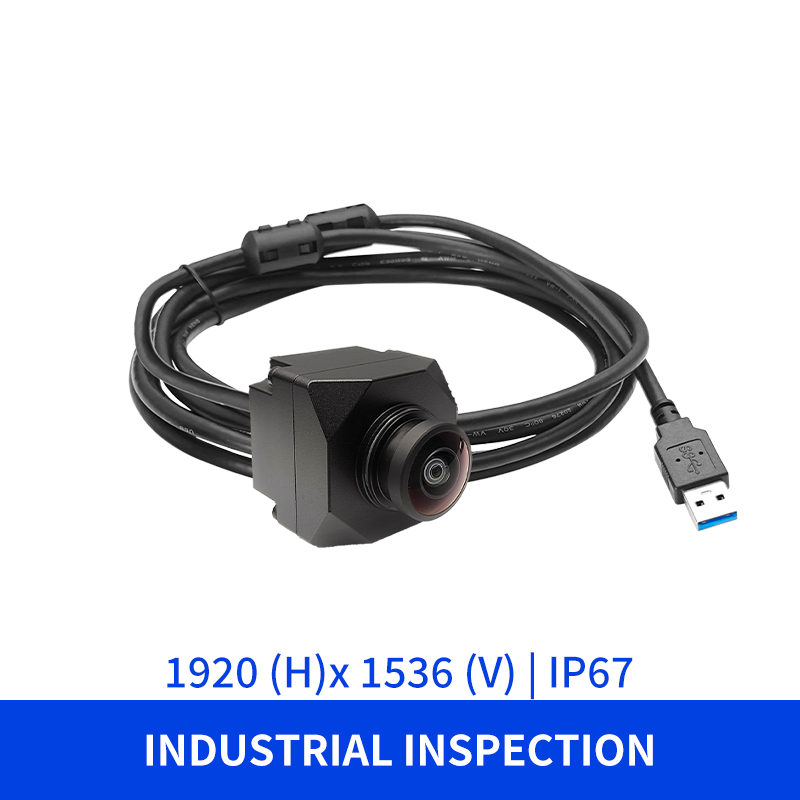
To address the challenges of spatial comprehension, motion coordination, and scene adaptation required for embodied intelligence in dynamic and complex environments, ALG-TECH introduces its robotic binocular camera series.
Through a differentiated dual-specification design, the series precisely caters to two core scenarios: head-mounted global perception and wrist-mounted fine perception. It empowers robots with end-to-end stereo vision capabilities—from environment mapping and object interaction to precise positioning and operational control—providing reliable visual support for intelligent tasks.
◊Scenario-Precise Adaptation
Features a differentiated dual-specification product design that simultaneously meets robots’ visual needs for large-scale global environment perception and close-range fine operational perception.
◊End-to-End Stereo Vision
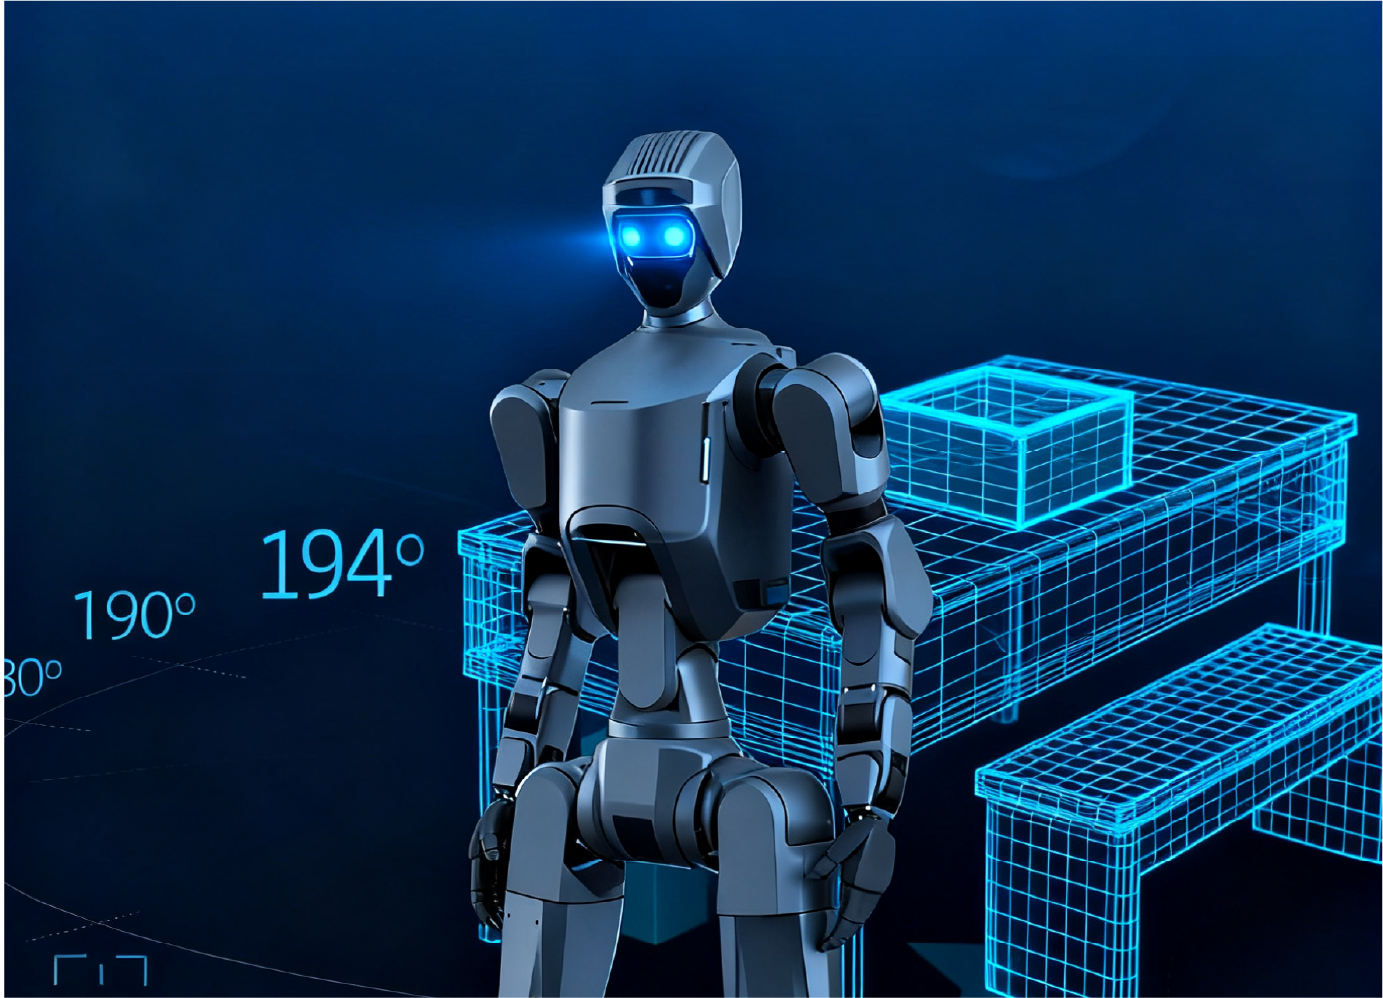
Provides humanoid robots with complete and coherent stereo vision capabilities, supporting environment 3D modeling, object recognition and interaction, as well as precise positioning and motion control, forming a closed loop of perception-decision-action.
◊Dynamic Environment Adaptability
Optimized for the challenges of dynamic and complex real-world operational environments, enhancing robots’ spatial understanding, real-time motion coordination, and scene adaptation capabilities.
◊Easy Integration and Deployment
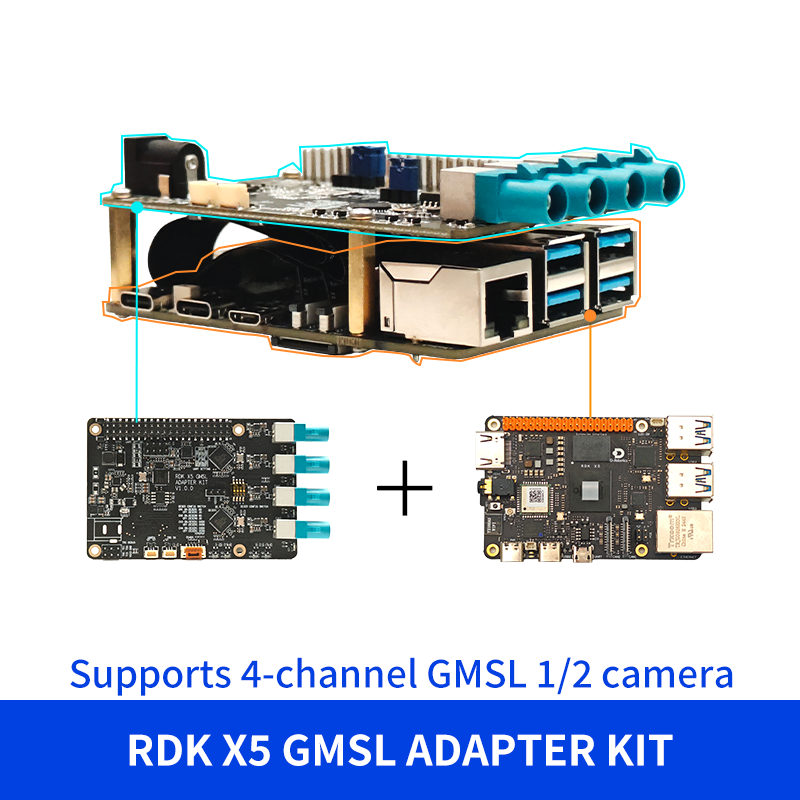
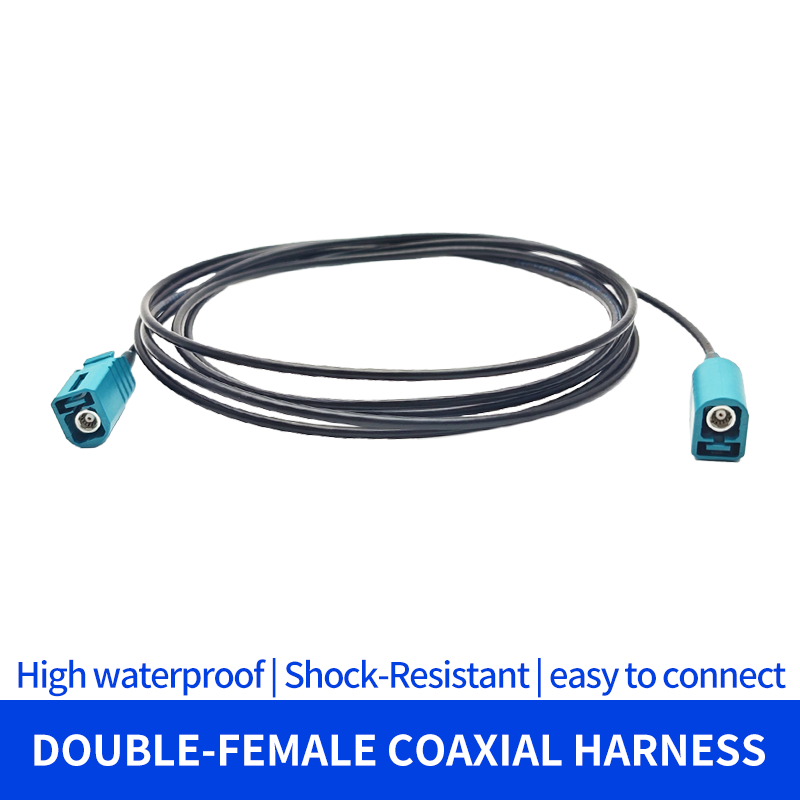
Offers anti-interference coaxial transmission capability over distances up to 15 meters, integrating Power over Coax (PoC) for both power and data transmission via a single cable, greatly simplifying wiring. The wrist camera integrates CAN/CANFD interfaces, enabling direct connection to gripper signals and transparent transmission to the main controller, further streamlining wrist cabling.
Related Products