Product Overview
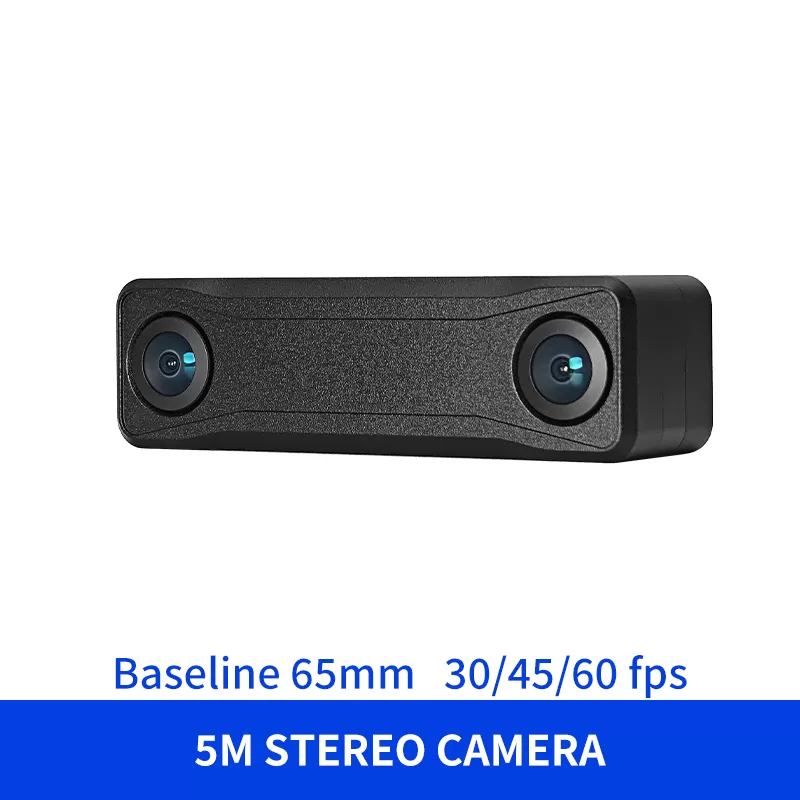
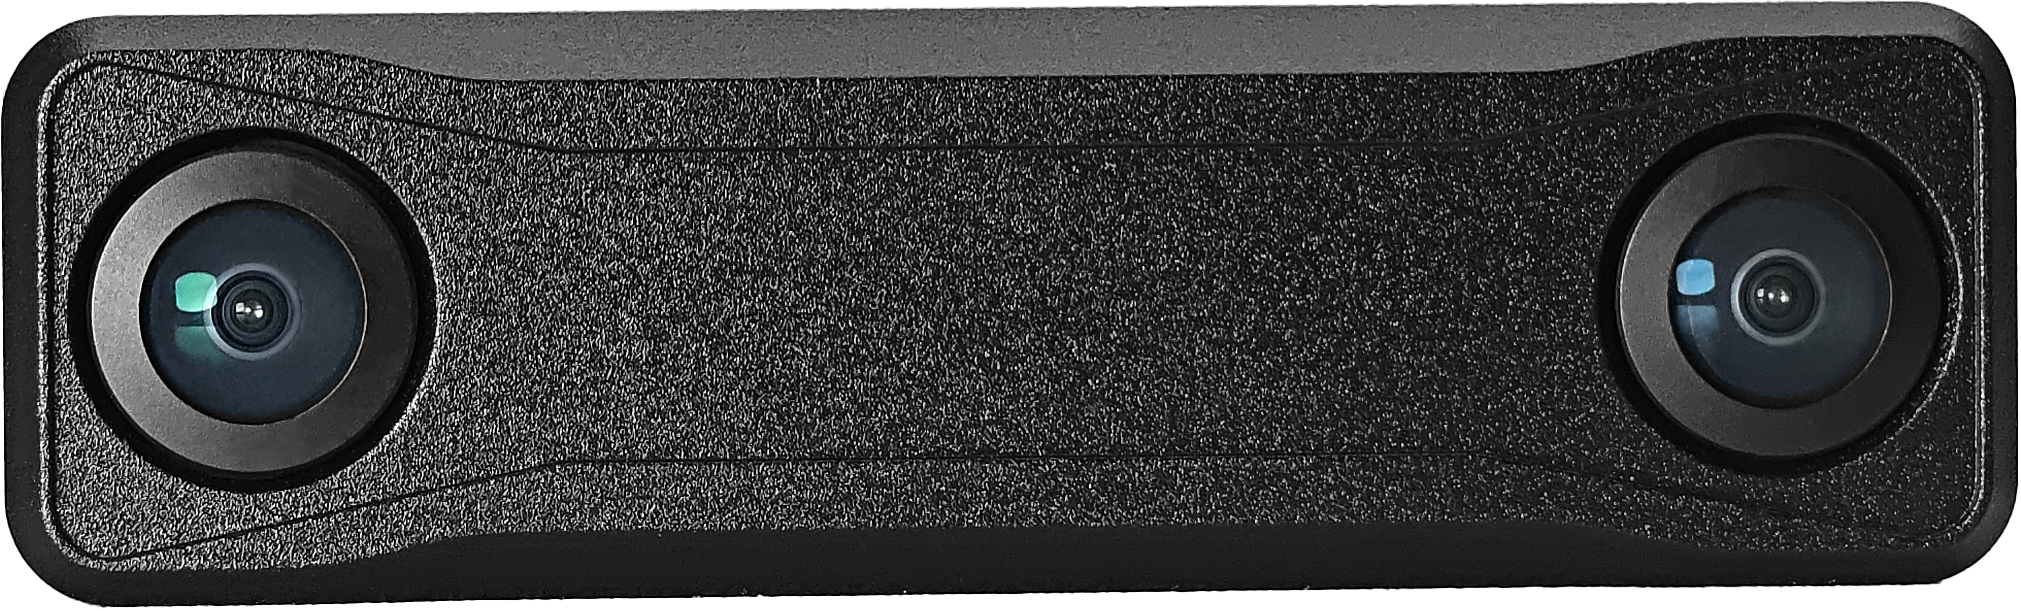
The AVS115D-Y is a 3/5-megapixel high-resolution GMSL stereo camera module purpose-built for industrial vision robots, designed to give autonomous machine systems precise, reliable visual perception.
Two high-performance image sensors output 3MP/5MP HD image data at up to 60 fps. Wide dynamic range (WDR) processing faithfully reproduces image detail in high-contrast scenes — backlight, low light, alternating bright/dark — effectively suppressing overexposure and smear to keep downstream vision and perception algorithms stable and reliable.
To handle the complex lighting challenges robots face, the module integrates a professional-grade ISP that performs image pre-processing on the camera side, including trigger-synced capture and synchronized auto-exposure timing — key features for stereo perception applications. A built-in 6-axis IMU is hardware-time-aligned with the vision data, providing a high-quality multi-modal fusion data source for downstream algorithms.
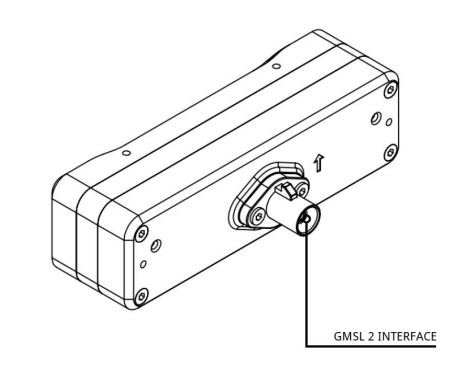
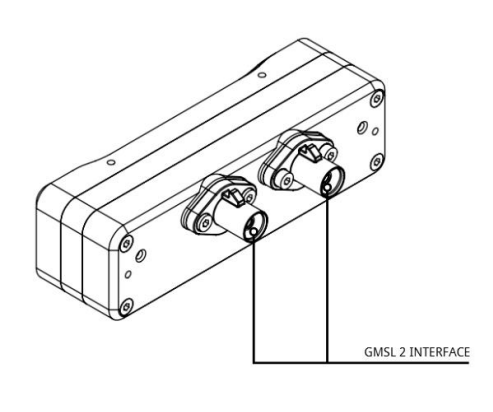
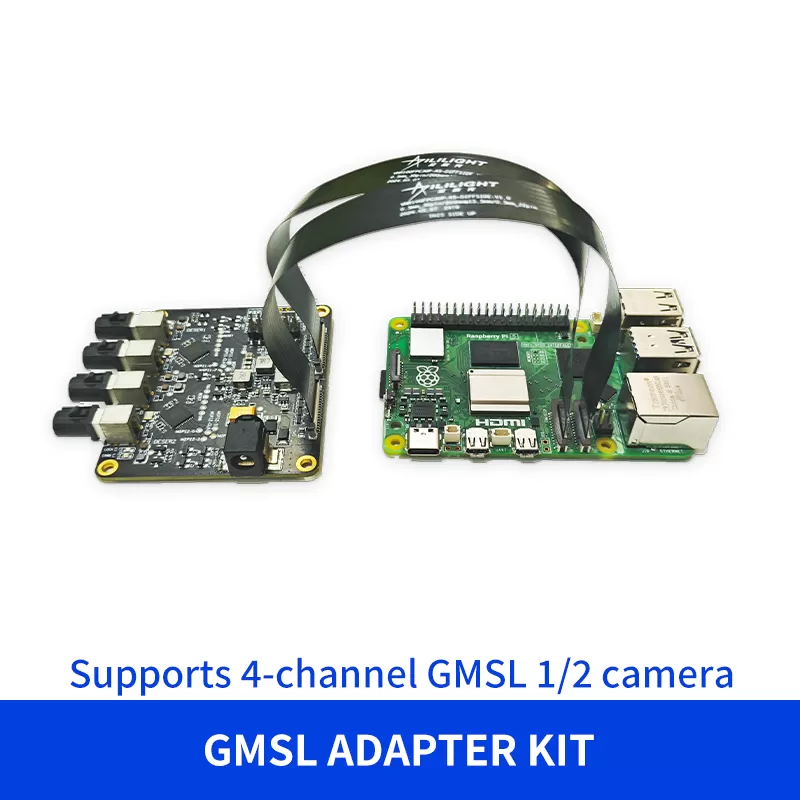
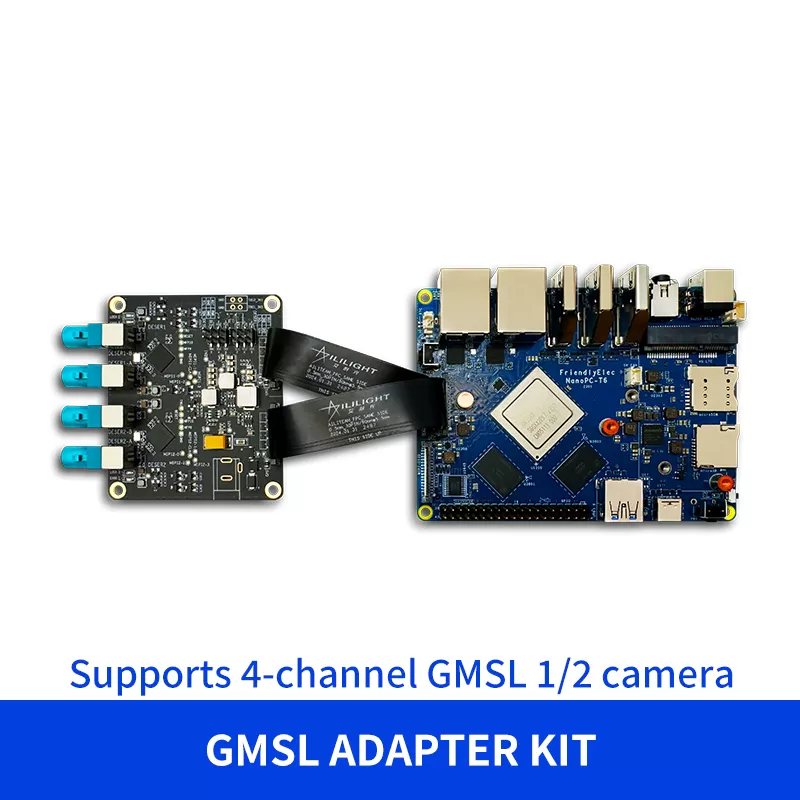
For connectivity, the module uses a GMSL (Gigabit Multimedia Serial Link) serial interface, achieving high-bandwidth, low-latency transmission over up to 15 meters of coaxial cable or shielded twisted pair with outstanding EMI immunity — simplifying the complex wiring between a robot’s head and its compute unit.
On the software side, a complete low-level driver and cross-platform SDK deeply support mainstream robot compute platforms across x86 (e.g., Intel) and ARM architectures (e.g., NVIDIA Jetson AGX Orin/NX, Rockchip) — accelerating the path from prototype validation to mass production.
In short, the AVS115D-Y combines high-resolution vision, ISP processing, multi-modal fusion perception, and flexible deployment into an ideal forward-looking, reliable solution for humanoid robots, AMRs/AGVs, industrial inspection, and other high-precision vision applications.
Key Features
-
High-Quality Imaging
Up to 60 fps image transmission.
Hardware-level stereo frame sync: both sensors are driven from the same clock source for pixel-level exposure synchronization, ensuring timing consistency for stereo matching.
Synchronized auto-exposure: left and right AE adjustment is strictly synchronized, keeping stereo images consistent in brightness and contrast.
Built-in high-performance ISP for on-camera image pre-processing. -
Multi-Modal Fusion
Built-in 6-axis IMU with accelerometer and gyroscope provides essential inertial data when vision fails — fast rotation, texture-poor scenes, and more.
-
Interface and System Design
Long-distance GMSL transmission: 15+ meters of high-bandwidth, low-latency transmission over coax or shielded twisted pair — fits the typical head-separate-from-compute robot architecture.
Single-cable power and video: video and power over one coaxial cable greatly simplifies wiring near mechanical joints and reduces cable wear risk. -
Flexible Multi-Platform Support
Driver interfaces for mainstream x86 and ARM platforms, with V4L2 and ROS framework support that lowers development complexity and accelerates integration and validation. An SDK enables depth computation on external devices.
Specification
| Basic information | |||
| Product Model | AVS115D-B06-M95DFA1-RABI | AVS115D-B06-M17G-G00-FA1-RABI | KZ-AVS115D-B06-M17G-G00-FA1-RABI |
| Product Name | 3/5MP Industrial GMSL Stereo Camera | ||
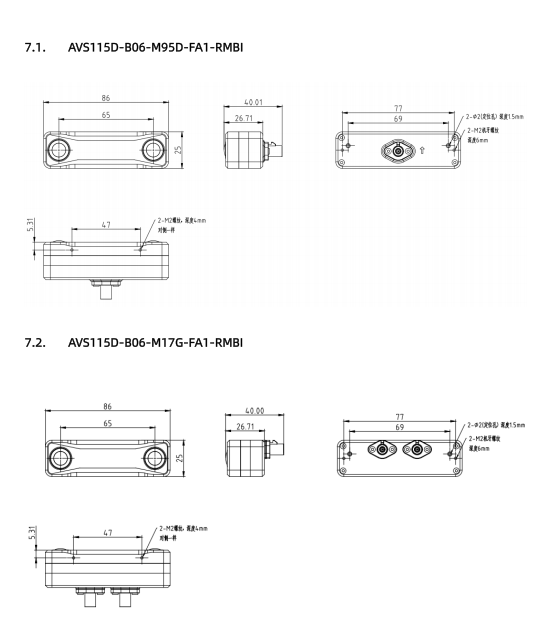
| Dimensions | 86 x 25 x 41.26 mm | ||
| Resolution | 1920 (H) x 1920 (V) | 2560 (H) x 1920 (V) | |
| HFOV | 119° | 119° | 165° |
| VFOV | 119° | ||
| Focal Length | 1.90 mm | ||
| Frame Rate | 30 fps | 60 fps | 45 fps |
| Output Format | YUV422 | ||
| Focus Distance | 0.8 m | ||
| Working Distance | 0.3 m – ∞ | ||
| Weight | 87 g | ||
| Depth Measurement | |||
| Baseline | 65 mm | ||
| Depth Range | 0.35–10 m (ideal) | ||
| Exposure Control | External trigger | ||
| Image Sensor | |||
| Optical Format | 1/2.7” CMOS | ||
| Pixel Size | 2.0 μm | ||
| Dynamic Range | 82 dB | ||
| Shutter Type | Rolling Shutter | ||
| Inertial Sensor | |||
| Accelerometer | 16-bit, ±2/4/8/16/32 g | ||
| Gyroscope | 16-bit, ±15.625–4000°/s | ||
| Data Rate | Configurable, up to 6400 Hz | ||
| Temperature Sensor | Built-in | ||
| Connectivity & Power | |||
| Transport Protocol | GMSL 2 | ||
| Image Output Interface | Fakra Z (SMBF-FKMX3-3GT30G50) | ||
| Power Supply | PoC (via GMSL) | ||
| Supply Voltage | 9–12 V | ||
| Rated Power | 2.3 W | ||
| SDK | |||
| Interface Protocols | V4L2 / ROS | ||
| Supported OS | Linux (Ubuntu) | ||
| Supported Architectures | x86 / ARM | ||
| Reliability | |||
| Operating Temperature | -20°C to +65°C | ||
Model Specifications
| Part Number | Description |
| AVS115D-B06-M95D-FA1-RABI | 1920 (H) x 1920 (V), 30 fps, H 119°, Slave mode, YUV422 output, standard FAKRA Z interface |
| AVS115D-B06-M17G-G00-FA1-RABI | 1920 (H) x 1920 (V), 60 fps, H 119°, Slave mode, YUV422 output, standard FAKRA Z interface |
| KZ-AVS115D-B06-M17G-G00-FA1-RABI | 2560 (H) x 1920 (V), 45 fps, H 165°, Slave mode, YUV422 output, standard FAKRA Z interface |
Dimensions
Typical Applications
Embodied Robots
The camera is mounted on the robot head. With a wide field‑of‑view for panoramic environmental perception, it accurately detects surrounding obstacles and spatial structures. It delivers real‑time and reliable depth information for robot path planning, autonomous navigation and human‑robot interaction, enabling advanced functions such as obstacle avoidance, object following and gesture recognition.
AGV/AMR Navigation and Dynamic Obstacle Avoidance
Provides real‑time stereo vision perception for autonomous mobile robots. It supports precise localization, dynamic obstacle detection, path planning and autonomous obstacle avoidance in indoor and outdoor environments, suitable for warehousing & logistics, smart factories, hospital delivery and other applications.
Interface Definition