Product Overview
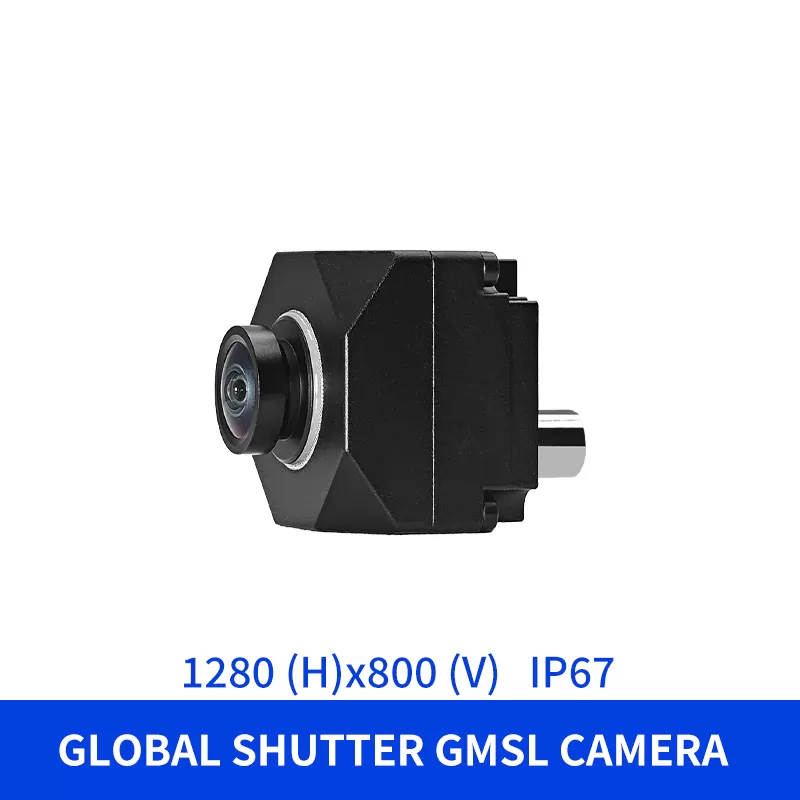
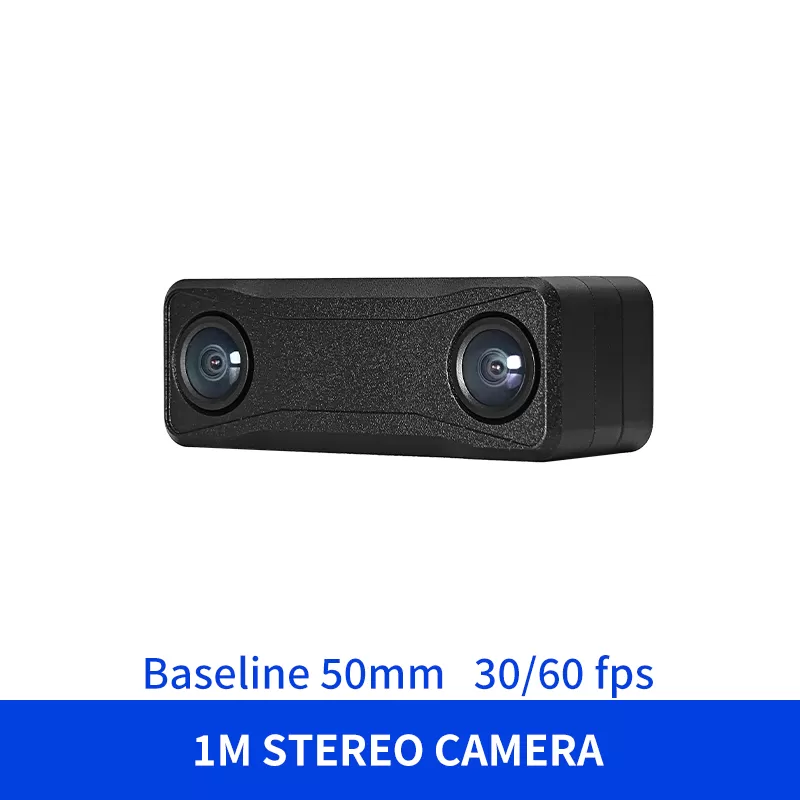
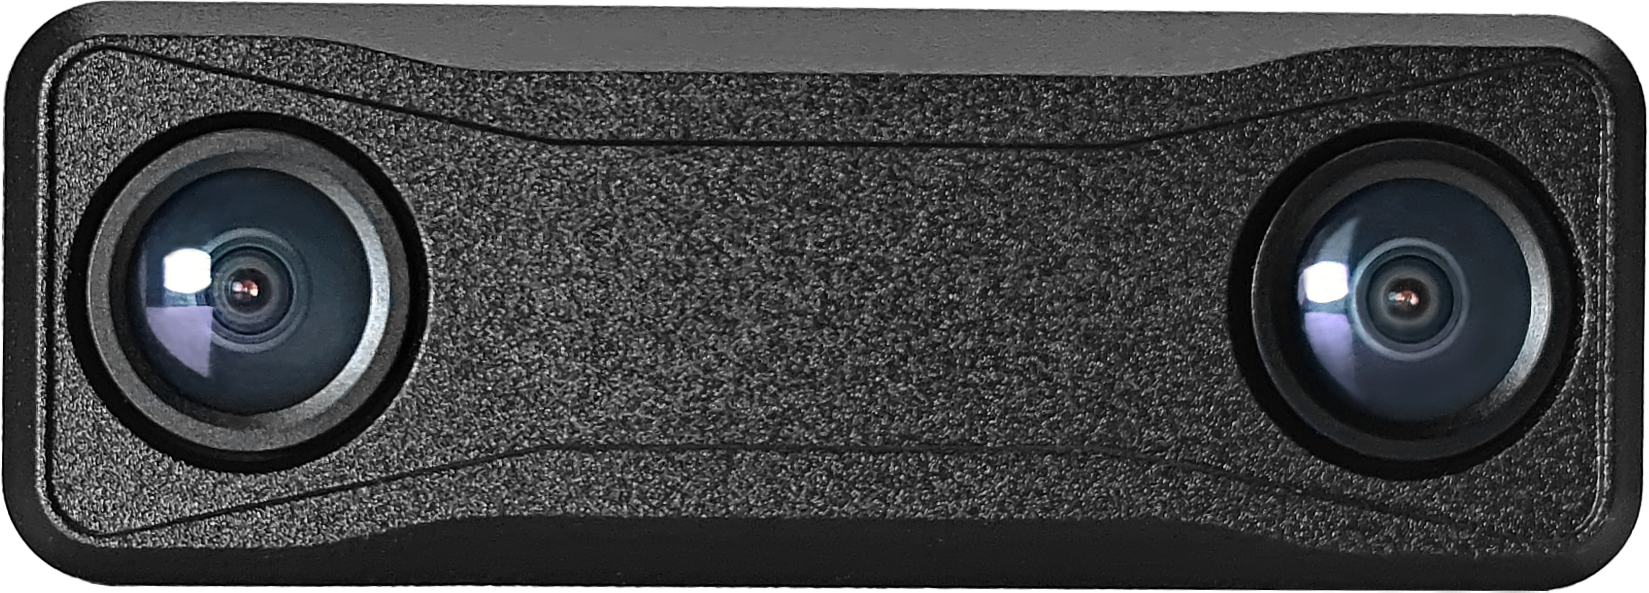
The AVS111C-Y is a 1MP industrial GMSL stereo camera module for embodied robotics and industrial automation. Its global-shutter technology delivers sharp, smear-free imaging even during fast motion and under complex lighting.
For depth sensing, the 50 mm stereo baseline provides stable depth measurement in the mid/near range — ideal for embodied robots and a wide variety of mid-to-close-range 3D perception scenarios. An integrated high-precision IMU supplies reliable attitude and acceleration data for motion compensation, VIO, and SLAM algorithms, further strengthening system stability and robustness in dynamic environments.
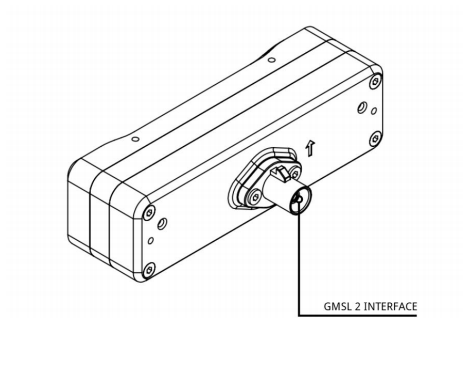
For data transmission, the AVS111C-Y uses the GMSL 2 protocol with high bandwidth and low latency, is powered via PoC, and provides an IIC/CAN interface (choose one) for direct connection to industrial control networks.
For module design, the AVS111C-Y innovatively separates the ISP board and the SerDes board, supporting fast adjustment, replacement, and customization for different project requirements — accelerating product development iterations and reducing system integration costs.
An SDK development kit is provided with support for mainstream platforms including x86 and ARM devices (e.g., Jetson, Raspberry Pi). The SDK is compatible with standard driver frameworks and common development environments such as V4L2 and ROS, helping users acquire data, build applications, and do secondary development quickly — significantly reducing overall development and integration effort.
Key Features
-
High-Quality Imaging
Global-shutter technology completely eliminates the rolling-shutter “jello effect” — perfect for high-speed motion scenes.
Ultra-wide field of view with a 120° horizontal FOV (HFOV) for broader environmental awareness.
High frame rate output up to 60 fps for demanding high-speed motion applications. -
Built-In IMU
Low-noise, low-power IMU provides 6-axis motion data for visual-inertial fusion.
-
Rich Peripheral Interfaces
Combined GMSL image-and-control signal transmission interface.
IIC/CAN interface for parameter configuration. -
GMSL 2 High-Bandwidth Transmission
Data is transmitted over the GMSL 2 (Gigabit Multimedia Serial Link) protocol, delivering high bandwidth and low latency with secure connectivity, strong interference immunity, and long transmission distances.
-
Modular Structural Design
Physically separate ISP and SerDes boards can be swapped quickly to adapt to different sensors, focal lengths, baselines, and interface options.
-
Flexible Multi-Platform Support
Driver interfaces for mainstream x86 and ARM platforms, with V4L2 and ROS framework support that lowers development complexity and accelerates integration and validation.
An SDK enables depth computation on external devices. -
Onboard Calibration for Rapid Deployment
Factory-calibrated with built-in parameters ready for user access.
Calibration parameters can be read and applied quickly.
Specification
| Item | Specification |
| Product Name | 1MP Industrial GMSL Stereo Camera Module |
| Model | AVS111C-B05-M17G-G52-GABI |
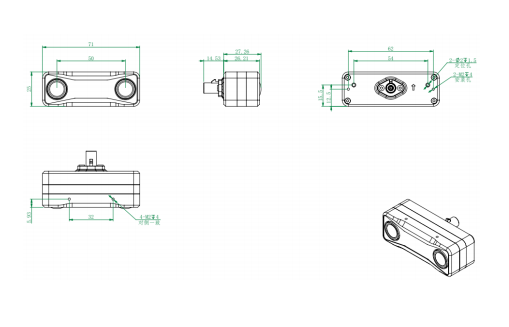
| Dimensions | 71 mm x 25 mm x 41.79 mm |
| Resolution | 1280 (H) x 800 (V) |
| HFOV | 120° (Horizontal) |
| VFOV | 76° |
| Focal Length | 1.67 mm |
| Frame Rate | 30/60 fps |
| Output Format | UYVY (YUV422) |
| Output Channels | Dual virtual channels |
| Focus Distance | 0.4 m |
| Working Distance | 0.05 m – 2 m |
| Weight | 79 g |
| Depth Measurement | |
| Baseline | 50 mm |
| Depth Range | 0.1 m – 2 m (ideal) |
| Exposure Control | Internal/external trigger supported (default: external) |
| Image Sensor | |
| Optical Format | 1/4.3” CMOS |
| Pixel Size | 2.8 μm |
| Shutter Type | Global Shutter |
| Inertial Sensor | |
| Accelerometer | 16-bit, ±2/4/8/16/32 g |
| Gyroscope | 16-bit, ±15.625–4000°/s |
| Data Rate | Up to 6400 Hz |
| Temperature Sensor | Built-in |
| Connectivity & Power | |
| Transport Protocol | GMSL 2 |
| Image Output Interface | Fakra Z (SMBF-FKMX3-3GT30G-50) |
| Power Supply | PoC (via GMSL) |
| Supply Voltage | 9–12 V |
| Rated Power | 1.1 W |
| SDK | |
| Interface Protocols | V4L2 / ROS |
| Supported OS | Linux (Ubuntu) |
| Supported Architectures | x86 / ARM |
| Reliability | |
| Operating Temperature | -20°C to +65°C |
Model Specifications
| Part Number | Description |
| AVS111C-B05-M17G-G52-GABI | 1280 (H) x 800 (V), 30 fps, HFOV 120°, dual virtual channel output, 6G mode, 50 mm baseline |
| AVS111C-B05-M17G-I00-G52-GABI | 1280 (H) x 800 (V), 30 fps, HFOV 120°, dual virtual channel output, IIC passthrough, 6G mode, 50 mm baseline |
| AVS111C-B05-M17G-C00-G52-GABI | 1280 (H) x 800 (V), 30 fps, HFOV 120°, dual virtual channel output, CAN support, 6G mode, 50 mm baseline |
Dimensions
Typical Applications
Embodied Robots
Hand‑eye coordination and grasping: Hardware synchronization between stereo camera and IMU enables high‑precision visual servoing. The system reliably grasps small objects such as cups, keys and mobile phones on the table, and achieves stable tracking and positioning even when the distance between objects and the robotic arm is only 15~30 cm.
AMR/AGV Robots (Logistics Warehousing & Unmanned Factory Handling)
Obstacle avoidance for ramps and pallet trucks: Combined with real‑time vehicle pitch angle sensed by IMU, the system detects pallet trucks and speed bumps ahead during uphill/downhill travelling, and automatically reduces speed or re‑plans the path.
Goods‑to‑person picking robots: After the robot docks at the workstation, the 120° field of view covers an entire shelf layer at one time. Operators standing at any position will not fall into blind zones, greatly improving safety.
Agricultural Automation & Unmanned Farms
3D localization and picking of fruits and branches: Global Shutter paired with 60fps imaging eliminates motion smear even under direct sunlight. High‑precision depth data supports accurate picking of overlapping fruits such as apples, strawberries and blueberries.
Precision navigation between crop rows: Mounted on the front of tractors or harvesting robots, the 120° field of view covers 3~4 crop rows. High‑precision depth maps are generated in real time for inter‑row navigation, suitable for tall stalk crops and vine crops including corn, tomatoes and grapes.
Interface Definition